Robotics · AI · Embedded Systems

Shivam Solanki

B.Tech IT (AI & Robotics) student at MITS Gwalior building real robotics systems — from fault-tolerant multi-robot task allocation to ROS2-driven embedded hardware products. Targeting CMU MRSD 2029.

▸ ROS2 Humble
▸ Python · OpenCV
▸ ESP32 · FreeRTOS
▸ Ubuntu 22.04
▸ MATLAB · Simulink
0Projects Shipped
0MathWorks Certs
2029CMU MRSD Target
500+LinkedIn Connections

Projects

01 — RESEARCH
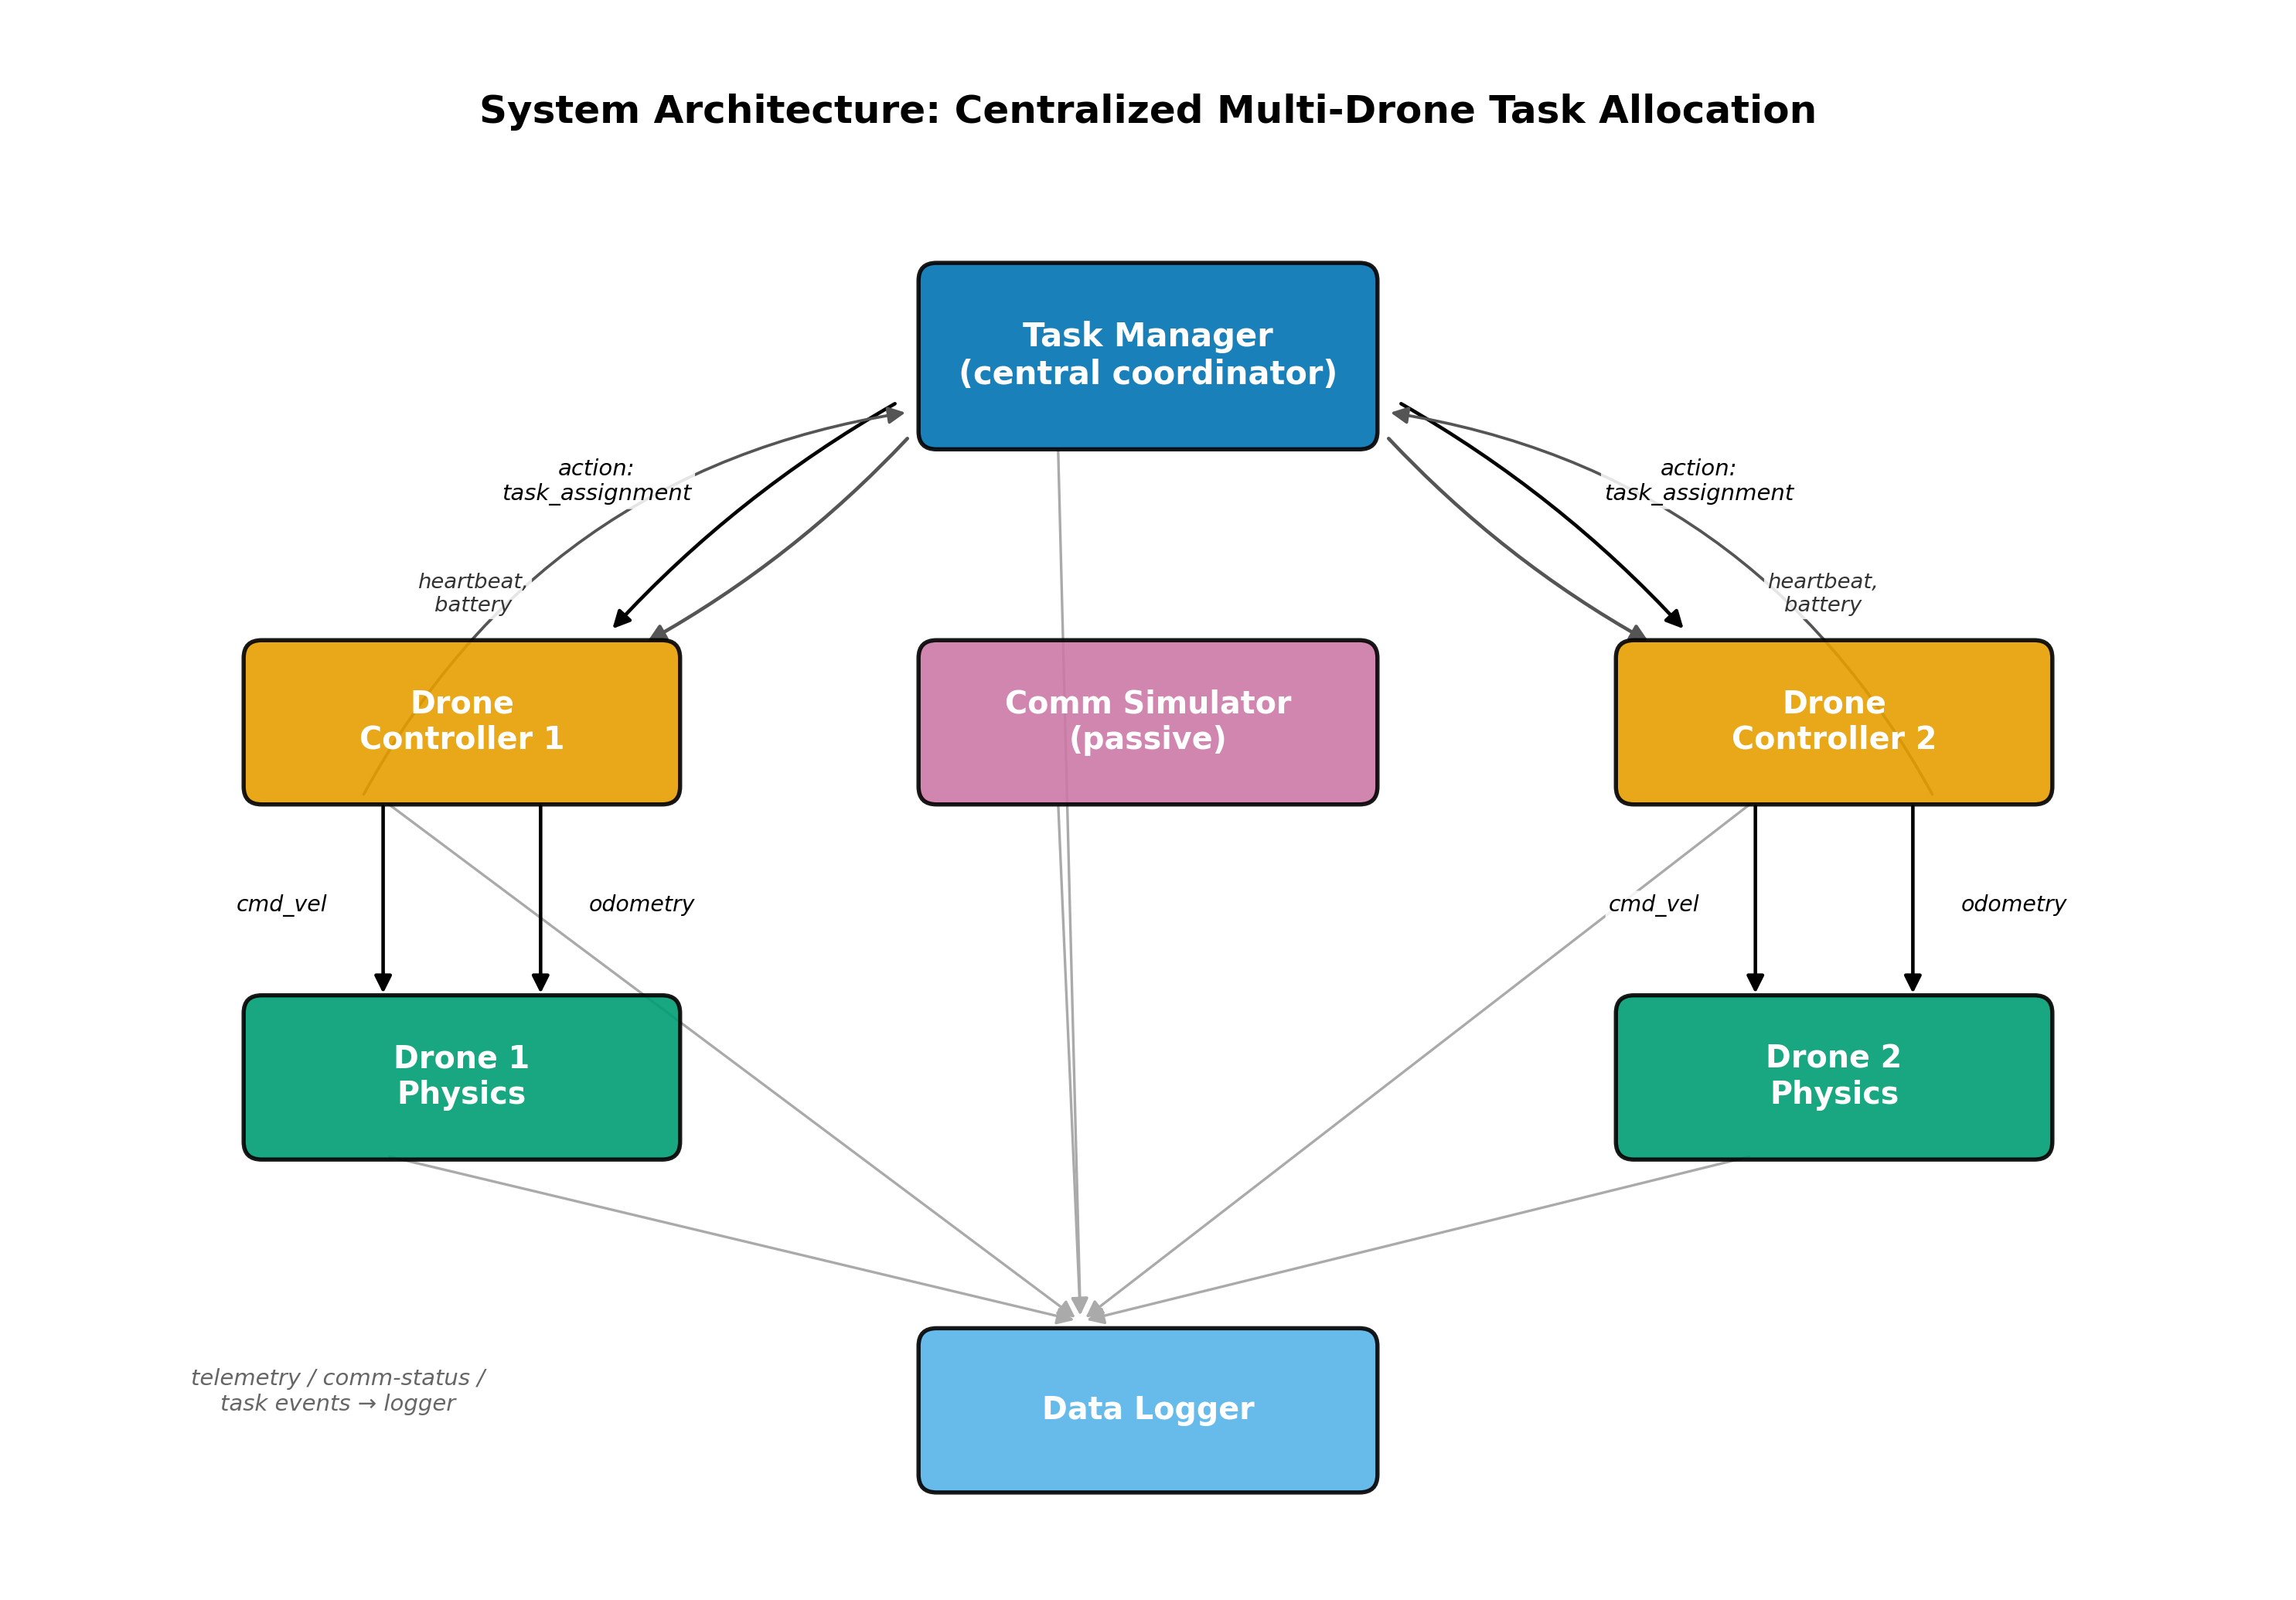
Fault-Tolerant Multi-Drone Task Allocation (ROS2)
System architecture diagram — centralized task manager coordinating two drone controllers via ROS2 actions

A centralized ROS2 system for multi-drone task allocation with explicit fault handling — distinguishing task-level failures from drone-level failures, and recovering from each differently. Includes a passive Gilbert-Elliott communication degradation model and a custom fault-injection framework (mid-task drone death, startup death, low battery). Evaluated across 250+ runs spanning 7 conditions. Manuscript in preparation for submission to IEEE RA-L.

ROS2 Humble Python Fault Tolerance Multi-Robot Systems Custom ROS2 Actions
02 — HARDWARE · PRODUCT
EON — Dual-Mode Autonomous/Manual Rover
PHOTOS / DEMO VIDEO
COMING SOON

A compact (7cm-cube) rover that switches between fully autonomous ROS2-driven navigation and manual control via a custom-built Bluetooth app. Built on ESP32, with ultrasonic obstacle sensing and a planned BME680 sensor for temperature and gas/VOC monitoring — aimed at applications like server-room surveillance and environmental early-warning. Currently the foundation for a personal hardware product line.

ESP32-S3 ROS2 Embedded C++ Bluetooth Product Design
03 — ROBOTICS
Three-Node ROS2 Sensor Pipeline

Complete 3-node publisher-subscriber pipeline with sensor publisher, data processor, and decision maker node. Live rqt_graph visualization showing all nodes communicating, launch file for simultaneous startup, and URDF robot model in RViz2. Demonstrates ROS2 architecture, message passing, and multi-node system design.

ROS2 Humble Python rclpy URDF RViz2
04 — EMBEDDED SIM
HC-SR04 Sensor Simulator with Real-Time Animation

Real-time simulation of HC-SR04 ultrasonic sensor with Gaussian noise modeling, spike injection, and bad reading detection. Dual-panel live animation updating every 50ms — raw readings over time + distribution histogram of valid data. Drop-in sim layer before real ESP32 hardware integration over WiFi UDP.

Python NumPy Matplotlib FuncAnimation HC-SR04
05 — COMPUTER VISION
HSV Real-Time Object Tracker

Webcam-based object tracking using HSV color segmentation and contour detection. Live trackbar UI for real-time HSV threshold tuning, morphological noise reduction, bounding box and centroid tracking at 30+ fps.

Python OpenCV NumPy HSV

Technical Skills

Robotics & Embedded
  • ROS2 Humble (rclpy, rclcpp)
  • ESP32 / FreeRTOS
  • URDF & RViz2
  • HC-SR04 Ultrasonic Sensors
  • Custom ROS2 Actions & Interfaces
Programming
  • Python (OpenCV, NumPy, Matplotlib)
  • C / C++ (Embedded)
  • Bash / Shell Scripting
  • Jupyter Notebook
Tools & Platforms
  • Ubuntu 22.04 (ARM64 VM)
  • Git & GitHub
  • MATLAB & Simulink
  • LaTeX (IEEE format)
  • macOS (M2 MacBook Air)
Concepts
  • Multi-Robot Task Allocation
  • Fault-Tolerant Systems Design
  • Sensor Fusion & Noise Modeling
  • SLAM (fundamentals)
  • Computer Vision (HSV segmentation)

Experience

AUG 2026 — PRESENT
Independent Hardware Project — EON Rover
Self-directed · MITS Gwalior
Designing and building a dual-mode (autonomous ROS2 / manual app-controlled) compact rover on ESP32, including sensor integration, power management, and product-level design decisions.
JUL — OCT 2026
Independent Researcher — Multi-Drone Task Allocation
Self-directed research · MITS Gwalior
Designed and implemented a centralized ROS2 task-allocation system with fault tolerance and communication-degradation modeling. Collected and analyzed 250+ experimental runs across 7 conditions. Preparing manuscript for submission to IEEE RA-L.
MAY — JUN 2026
Independent Developer — Summer Robotics Sprint
Self-directed · GitHub: shivam-robotics
Built a complete ROS2 sensor pipeline, HC-SR04 noise-modeled simulator, and HSV object tracker. Set up Ubuntu 22.04 ARM64 VM on M2 MacBook. Pushed all projects to GitHub with full READMEs.

Certifications

About

I'm a second-year B.Tech student in Information Technology (AI & Robotics) at Madhav Institute of Technology & Science, Gwalior. My work lives at the intersection of robotics software and embedded hardware — building things that move, sense, and respond.

From designing a fault-tolerant multi-drone task-allocation system and running it through 250+ experimental trials, to building EON — a dual-mode autonomous/manual rover on ESP32 — I care deeply about understanding systems end-to-end, not just running code, but knowing why it works and how it fails.

Outside of robotics, I'm into calisthenics and boxing, and I'm building the discipline, consistency, and grit that engineering at the highest level demands.

Long-term Target
MRSD
Carnegie Mellon University
Robotics Institute
Planned entry: Fall 2029 · Building toward this with every project, certification, and research contribution.
CMU MRSD 2029

Get in Touch

Open to research collaborations, internship opportunities, and conversations about robotics, ROS2, and embedded systems.