Projects
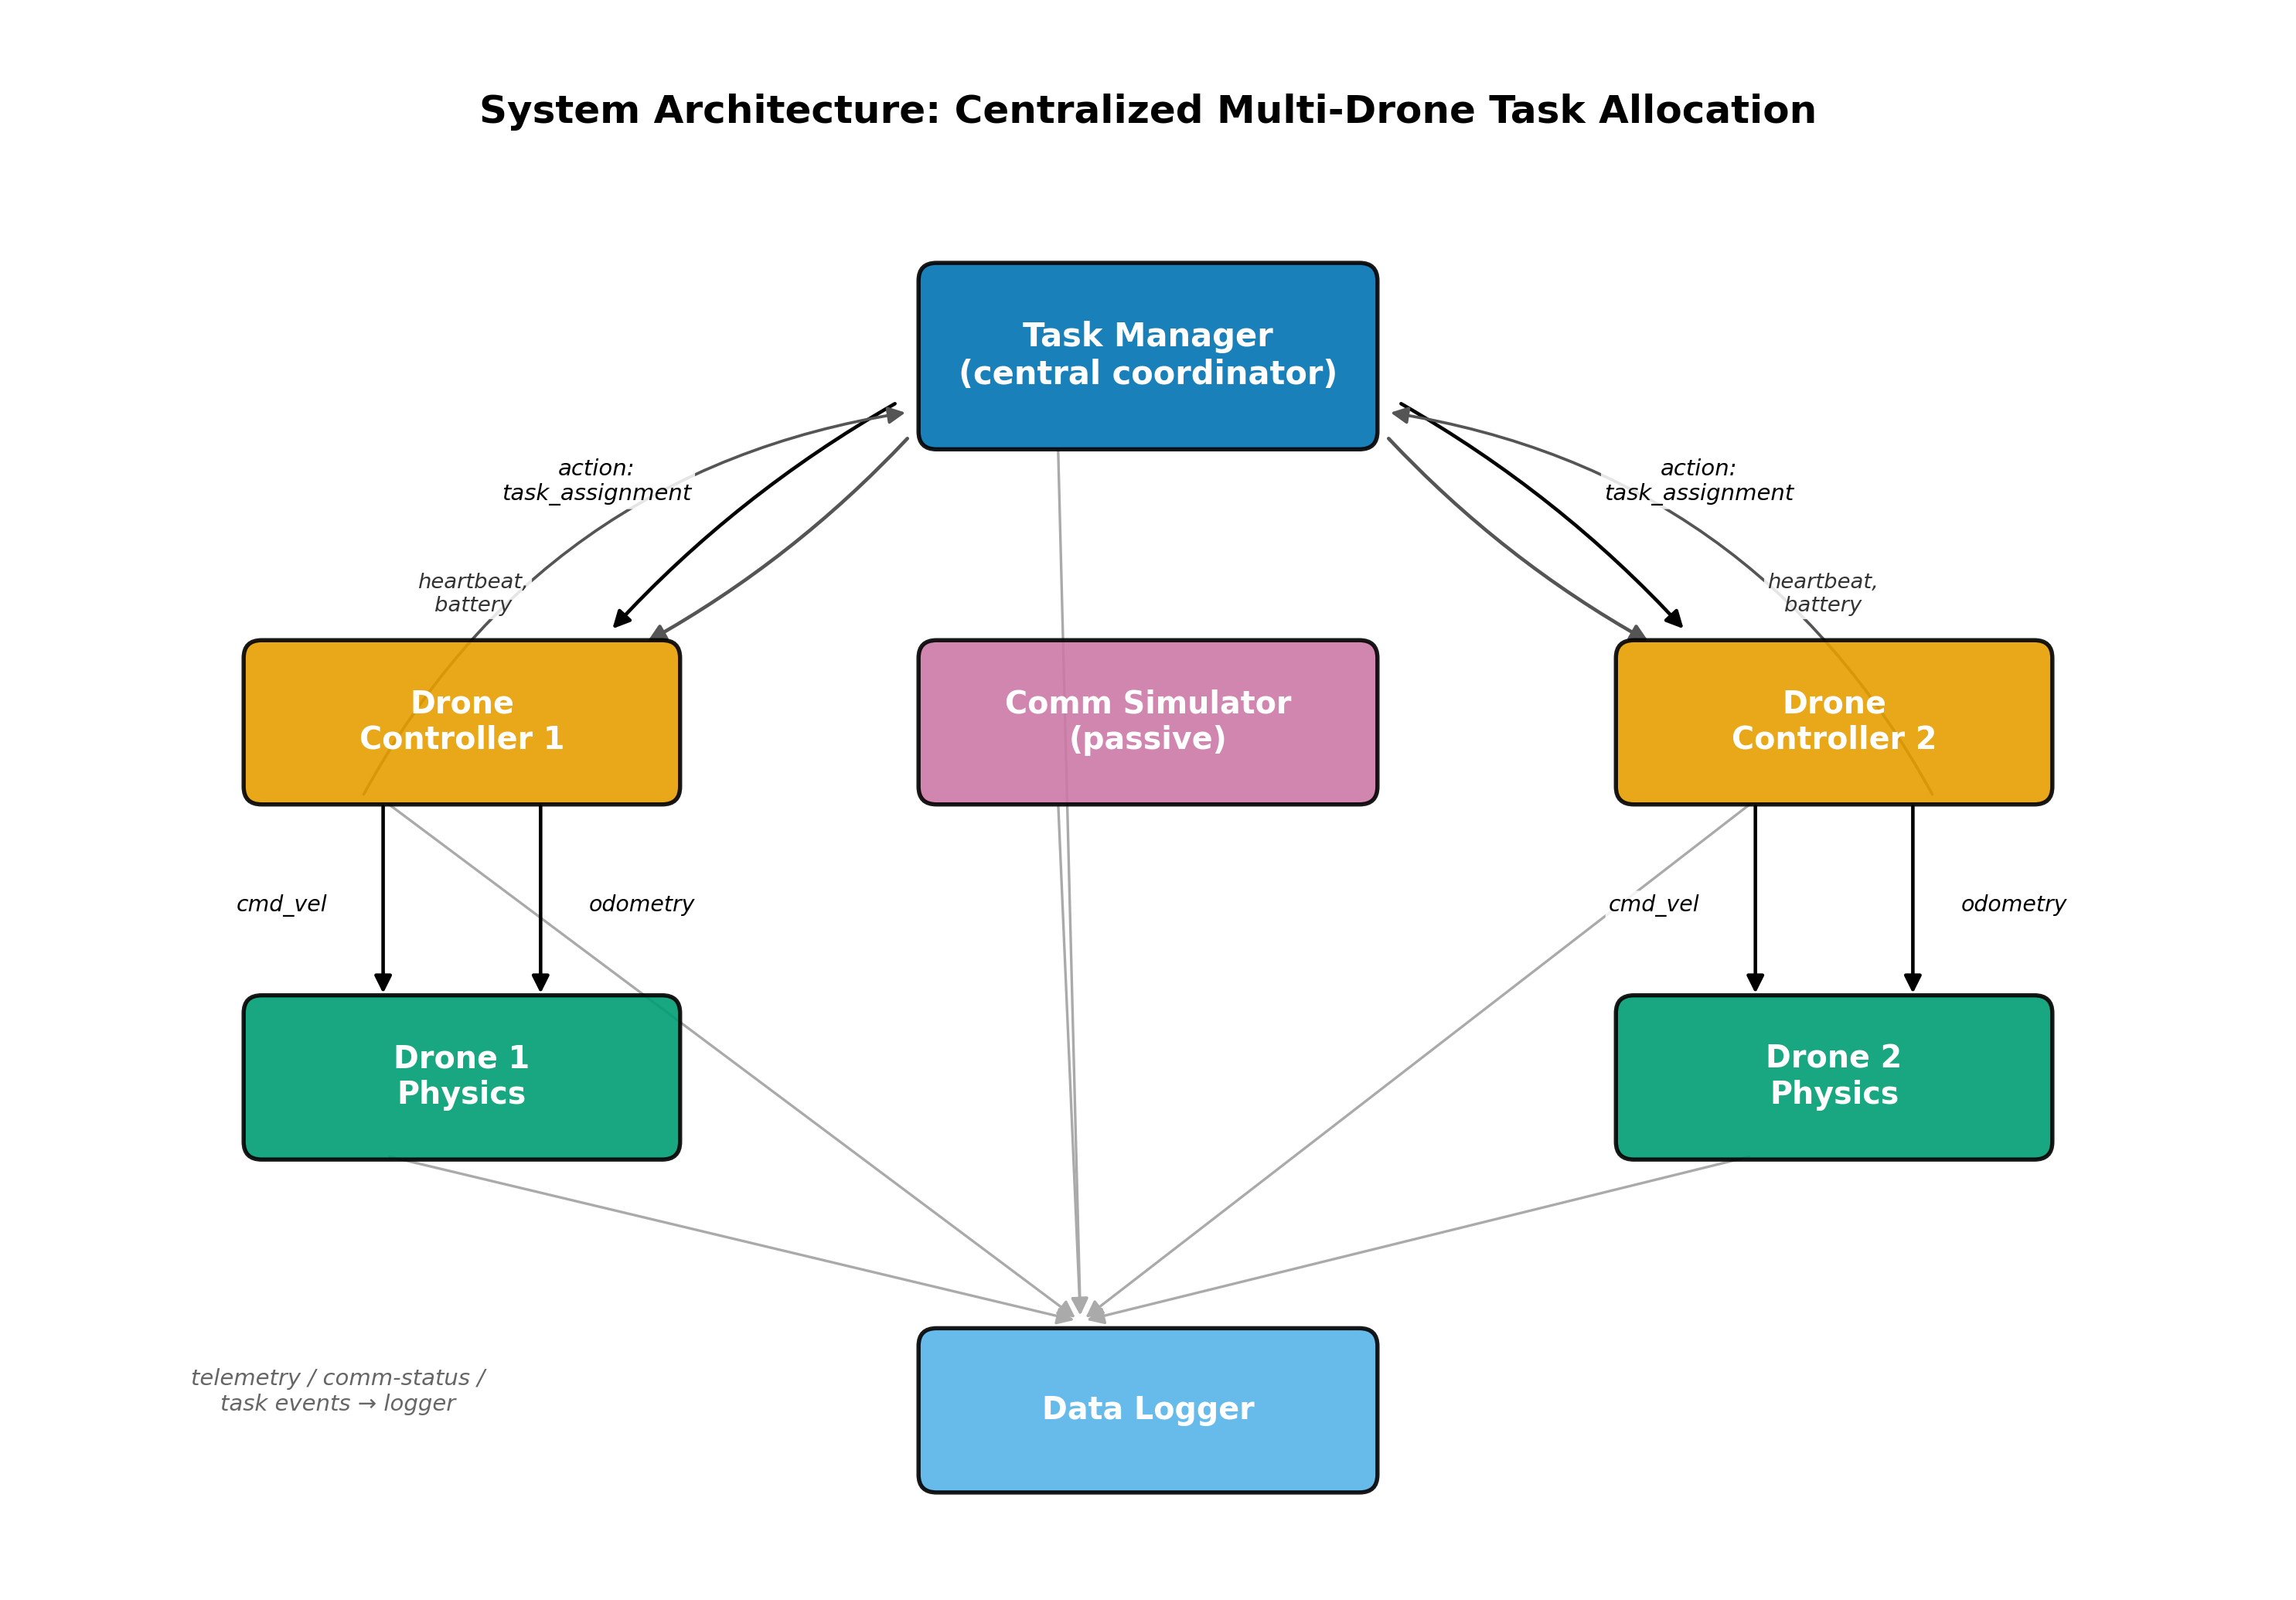
A centralized ROS2 system for multi-drone task allocation with explicit fault handling — distinguishing task-level failures from drone-level failures, and recovering from each differently. Includes a passive Gilbert-Elliott communication degradation model and a custom fault-injection framework (mid-task drone death, startup death, low battery). Evaluated across 250+ runs spanning 7 conditions. Manuscript in preparation for submission to IEEE RA-L.
COMING SOON
A compact (7cm-cube) rover that switches between fully autonomous ROS2-driven navigation and manual control via a custom-built Bluetooth app. Built on ESP32, with ultrasonic obstacle sensing and a planned BME680 sensor for temperature and gas/VOC monitoring — aimed at applications like server-room surveillance and environmental early-warning. Currently the foundation for a personal hardware product line.
Complete 3-node publisher-subscriber pipeline with sensor publisher, data processor, and decision maker node. Live rqt_graph visualization showing all nodes communicating, launch file for simultaneous startup, and URDF robot model in RViz2. Demonstrates ROS2 architecture, message passing, and multi-node system design.
Real-time simulation of HC-SR04 ultrasonic sensor with Gaussian noise modeling, spike injection, and bad reading detection. Dual-panel live animation updating every 50ms — raw readings over time + distribution histogram of valid data. Drop-in sim layer before real ESP32 hardware integration over WiFi UDP.
Webcam-based object tracking using HSV color segmentation and contour detection. Live trackbar UI for real-time HSV threshold tuning, morphological noise reduction, bounding box and centroid tracking at 30+ fps.